PAMTRI: Pose-Aware Multi-Task Learning for Vehicle Re-Identification Using Highly Randomized Synthetic Data
ICCV 2019
Summary
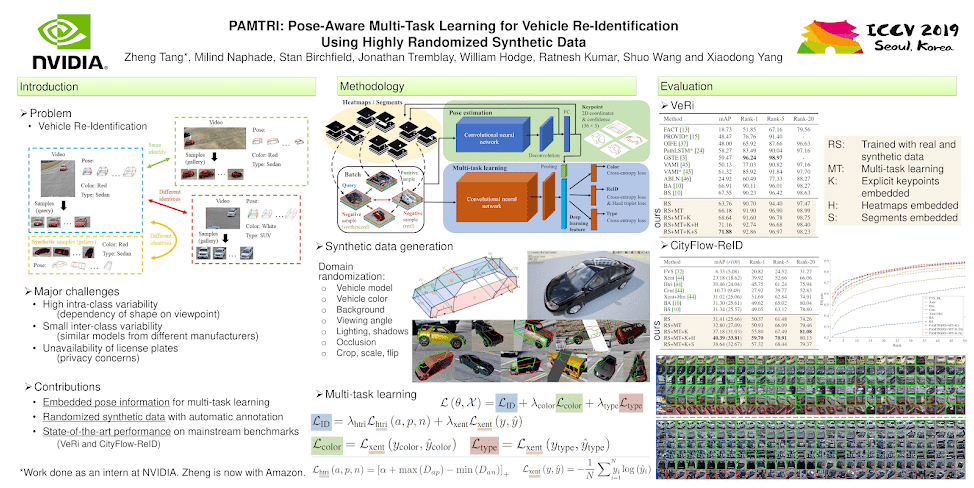
PAMTRI combines vehicle re-identification with pose estimation and attribute learning. Pose keypoints, heatmaps, and segments help address viewpoint variation, while joint color and type prediction provide additional supervision. Highly randomized synthetic vehicles supply pose and attribute labels without manual annotation. Experiments on VeRi and CityFlow-ReID evaluate the contribution of each component to cross-camera vehicle matching.
Citation
@inproceedings{Tang19PAMTRI,
  author = {Zheng Tang and Milind Naphade and Stan Birchfield and Jonathan Tremblay and William Hodge and Ratnesh Kumar and Shuo Wang and Xiaodong Yang},
  title = { {PAMTRI}: {P}ose-aware multi-task learning for vehicle re-identification using highly randomized synthetic data},
  booktitle = {Proc. ICCV},
  pages = {211--220},
  address = {Seoul, Korea},
  year = {2019}
}