Single-Camera and Inter-Camera Vehicle Tracking and 3D Speed Estimation Based on Fusion of Visual and Semantic Features
CVPR Workshops 2018
Summary
This work combines visual and semantic features for vehicle tracking within and across non-overlapping cameras. Adaptive appearance models and trajectory cues support single-camera association; deep features, license-plate cues, and vehicle types support cross-camera re-identification. Evolutionary camera calibration enables 3D speed estimation. The system achieved the top results in both traffic flow analysis and vehicle re-identification at the 2018 AI City Challenge.
Recognition
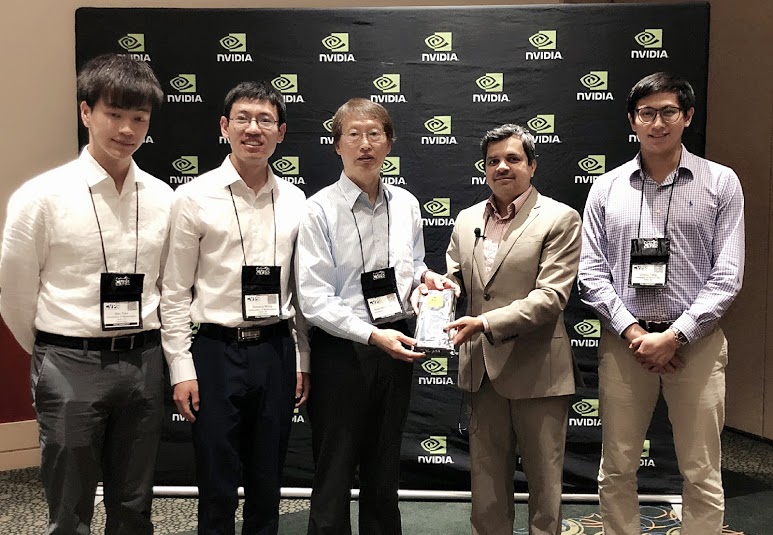
- Winner of Track 1 (Traffic Flow Analysis) at the 2nd AI City Challenge Workshop in CVPR 2018
- Winner of Track 3 (Multi-camera Vehicle Detection & ReID) at the 2nd AI City Challenge Workshop in CVPR 2018
Citation
@inproceedings{Tang18AICity18ICT,
  author = {Zheng Tang and Gaoang Wang and Hao Xiao and Aotian Zheng and Jenq-Neng Hwang},
  title = {Single-camera and inter-camera vehicle tracking and {3D} speed estimation based on fusion of visual and semantic features},
  booktitle = {Proc. CVPR Workshops},
  pages = {108--115},
  address = {Salt Lake City, UT, USA},
  year = {2018}
}