Metropolis spatial AI in the Mega Omniverse Blueprint at CES 2025
Published:
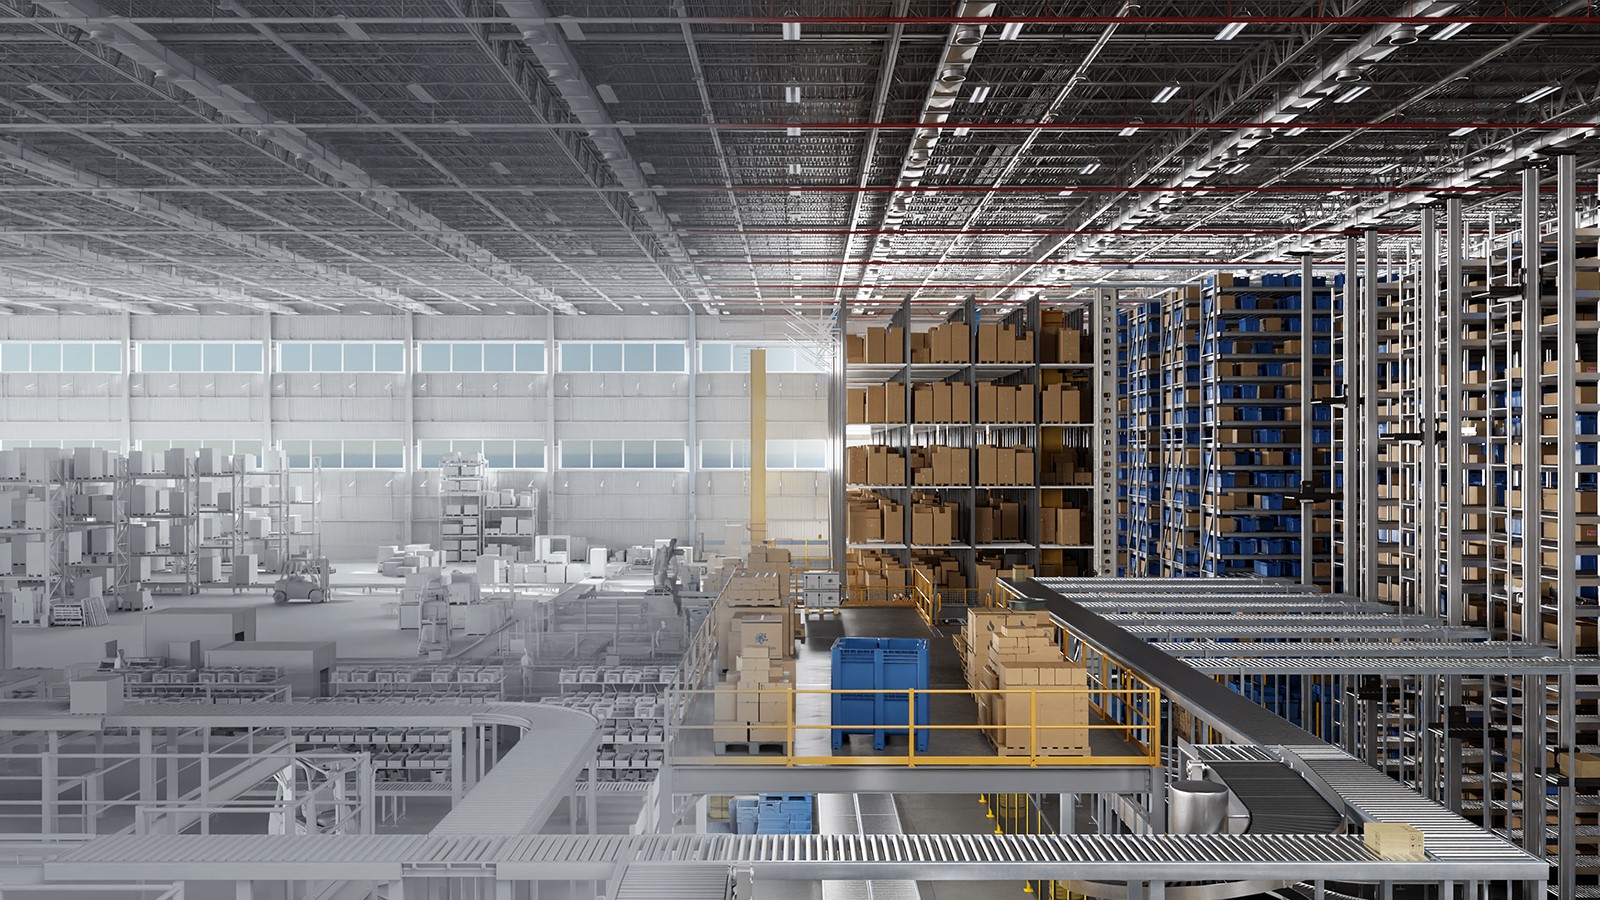
Our Metropolis spatial AI work was featured in Jensen Huang’s CES 2025 keynote as part of the Mega Omniverse Blueprint. I helped lead the Metropolis perception work integrated into the demonstration.
Highlights
- Multi-camera tracking and real-time location systems connect camera observations to the positions of people, vehicles, and robots in industrial spaces.
- Our perception contribution included BEV-SUSHI for 3D understanding and graph-based tracking for cross-camera association.
- Collaboration across Metropolis, Omniverse, and Isaac Sim teams connected these capabilities with digital-twin workflows for simulation and testing before deployment.